Materials Mechanics
Monocular 3D Video Extensometer


Monocular 2D Optical Strain Measurement System
Monocular 3D Optical Strain Measurement System
High-Speed Monocular 3D Optical Strain Measurement System
Stereo 3D Optical Strain Measurement System
Optical Strain Measurement System – Educational Edition
2D Optical Microscopic Strain Measurement System


Strain Measurement of Parallel Lap Welds
Residual Deformation Measurement of Drilled Welded Plates
Full-Field Strain Measurement of Weldments in Compression
Tensile Deformation Measurement of 0.3mm Fiber Filament
Unmarked Compression Deformation Measurement of Composite Materials

Deformation Measurement of Artificial Cardiac Patch
Keycap Vibration Measurement: Quantifying Press and Rebound Dynamics
Headband Deformation Measurement: Analyzing Bending Position and Unloading Recovery
High-Temperature DIC Measurement of Wafer Thermal Warpage: Quantifying Warpage vs. Temperature
UAV Dynamic Tracking Measurement: Capturing Flight Trajectory and Attitude Changes

 0755-86347753
 PRODUCT
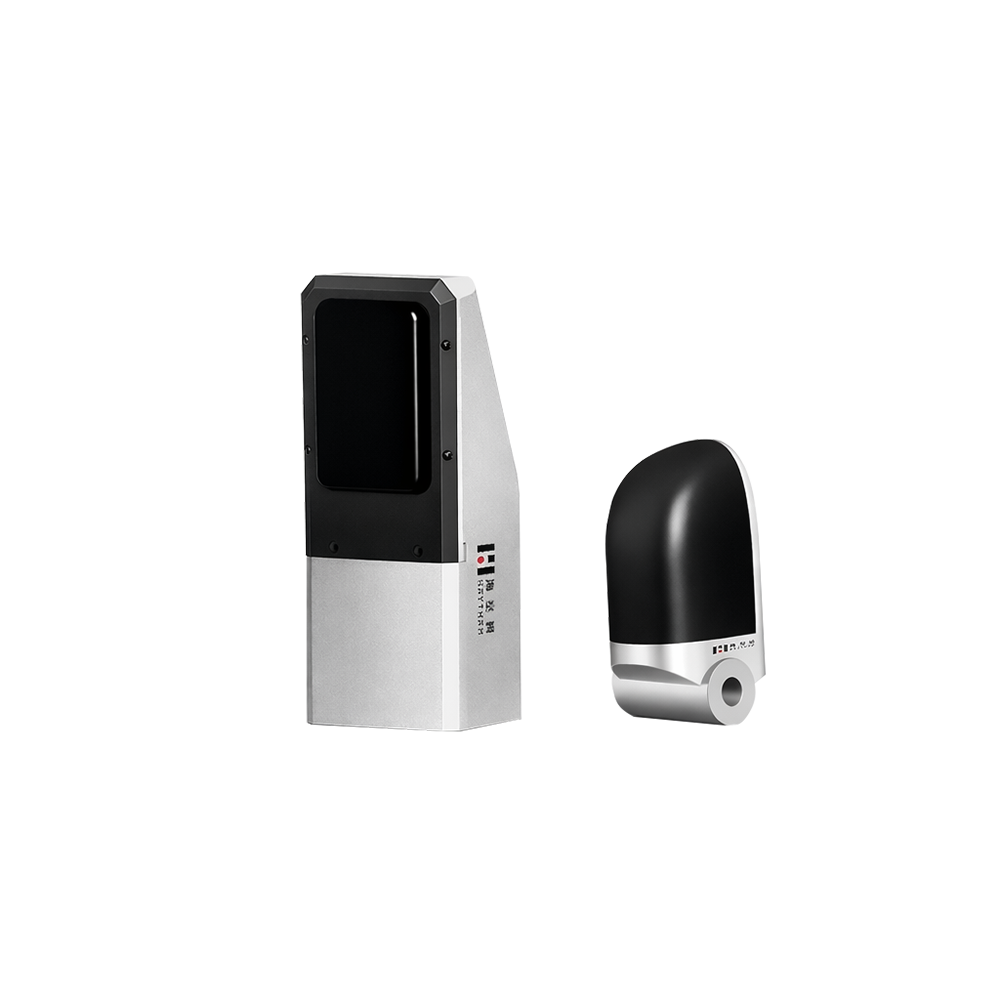
A multimodal tactile sensing solution based on DIC vision measurement technology
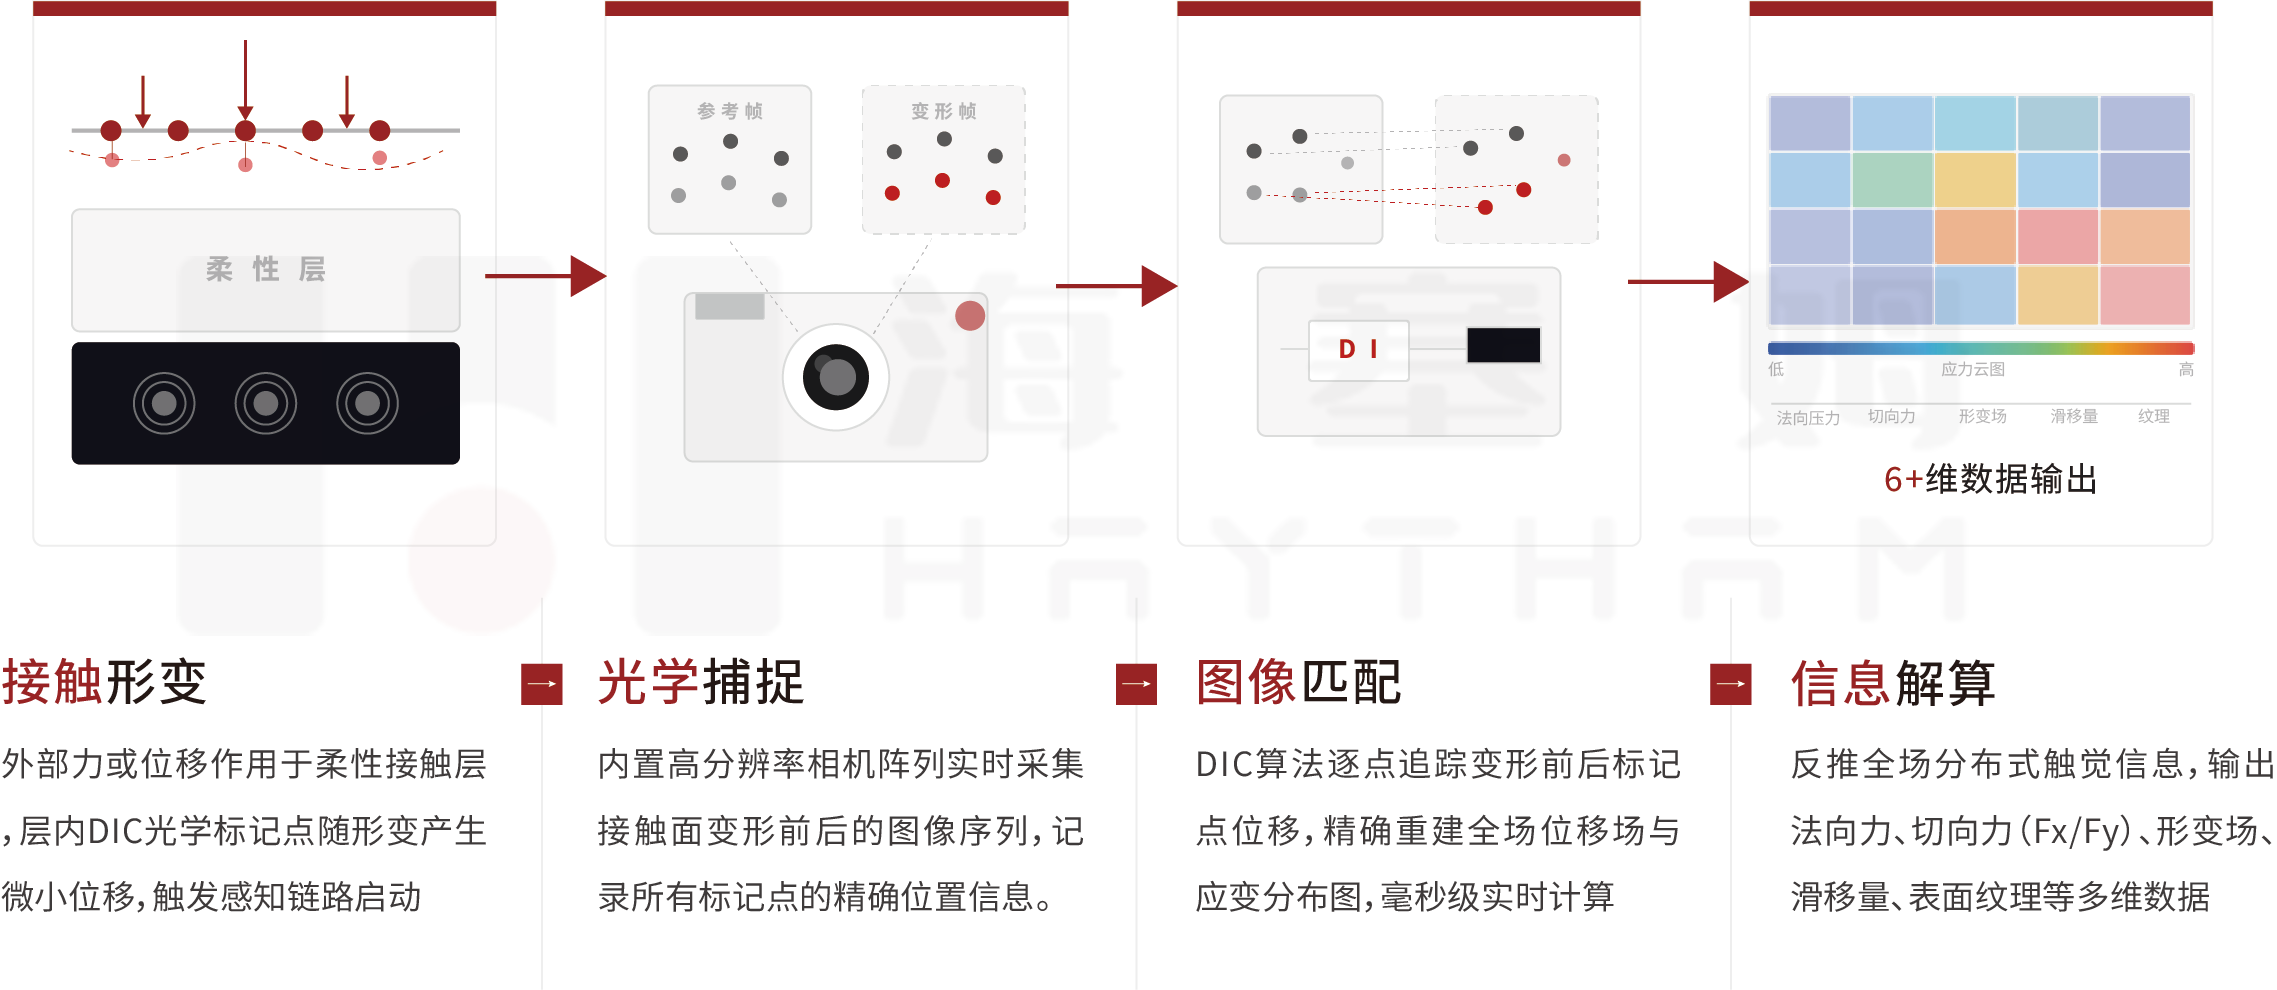
The DIC visuotactile sensor is a multimodal intelligent sensor that combines visual perception with tactile feedback. Through optical imaging and DIC image analysis technology, the product senses and resolves information such as deformation, pressure, displacement, slip, texture, normal force, and tangential force during object contact, achieving high-precision, high-resolution, full-field distributed contact state measurement and mechanical force sensing.
Designed for robotic dexterous manipulation, fine grasping, and complex contact control scenarios, the DIC visuotactile sensor provides the system with more comprehensive, more detailed, and more stable tactile data support.
 Downloads

